Rising requirements for precision and performance expose the limits of conventional electronic actuators: friction and backlash in the gear train create non-linear behaviour that causes hunting during opening modulation and unnecessary frequent movement; performance also drifts with running direction, mechanical wear and load, so the actuator struggles to hold position. The answer is digitalisation, intelligence — and networked control. Major international instrument makers now offer Profibus-fieldbus actuators, and domestic makers are following. This article presents the structure, control algorithm and software design of a fieldbus-based intelligent electric actuator.
1. System composition
The actuator comprises a controller, servo motor, position detection and gear reducer (Fig. 1). The controller acquires the valve setpoint (sent by the supervising device over the fieldbus interface) and the position feedback (linear displacement x or angular θ through the position detector as Uf); the controller output passes a thyristor-based relay-type non-linear stage to drive the motor and reducer.
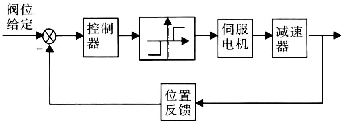
Fig.1 Composition of the electric actuator
2. Controller hardware
The hardware consists of the actuator control unit and a PROFIBUS-DP slave interface unit (Fig. 2), designed modularly with a dual CPU: a dsPIC30F6012A for actuator control and an AT89C55 for the bus interface, exchanging control and status data over a serial link.
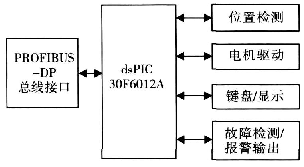
Fig.2 Controller hardware structure
1. Control unit: position detection (conductive-plastic precision potentiometer), central processing, motor drive (solid-state relays with forward/reverse interlocking), keypad/display (dot-matrix LCD) and alarm I/O (opto-isolated limit and overheat signals).
2. PROFIBUS-DP slave interface: built on the intelligent SPC3 protocol chip (Fig. 3).
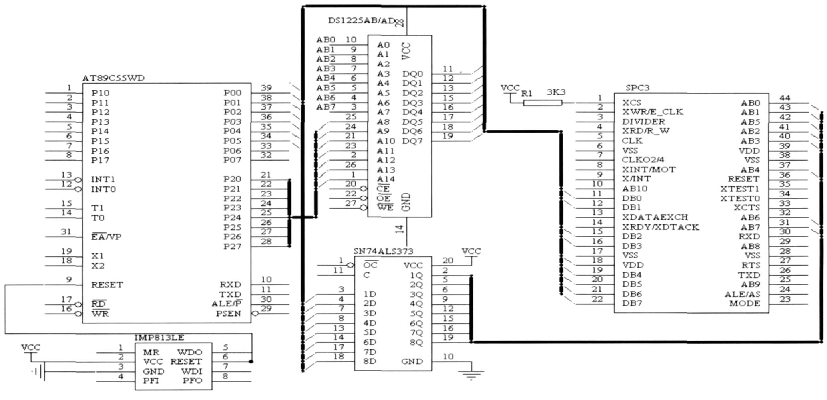
Fig.3 PROFIBUS-DP slave interface hardware
3. Intelligent control algorithm and software
1. Algorithm: dead-band relay stages alone cannot suppress hunting from insensitivity, backlash and friction. A fuzzy-control stage is therefore superimposed: position error E and error change EC drive an expert rule table (Table 1) that determines the output H and motor start/stop commands. Fuzzy sets are {NL, NM, NS, ZO, PS, PM, PL}; universes are set from motor and gearbox parameters by expert experience.
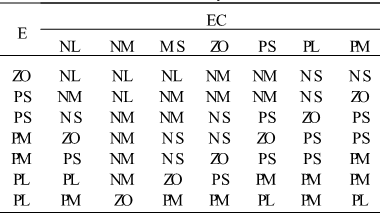
Table 1 Fuzzy rules
2. Software: two parts — control-unit firmware (dsPIC30F, C30: init, data acquisition, intelligent control algorithm, motor drive, keypad/display, fault detection/alarm, menus, serial and timer interrupts) and bus-interface firmware (C51: PROFIBUS-DP slave functions + serial communication). The main program flow is shown in Fig. 4.
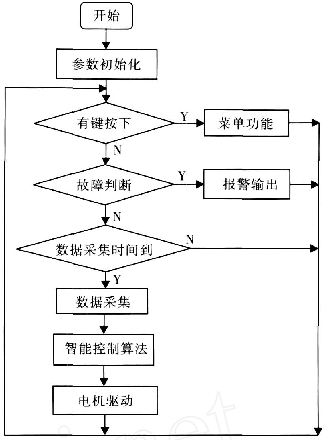
Fig.4 Main program flow
4. Conclusion
A 16-bit-dsp-based fieldbus intelligent actuator with a PROFIBUS-DP slave design gains networking capability, with fuzzy control improving quality. A 48-hour loaded prototype test showed stable performance and 0.5% control accuracy — suitable for industrial field environments.
We supply intelligent actuators with Profibus/Modbus and other fieldbus interfaces, plus system-integration support — contact us.






