Fig. 1 Superheater outlet temperature control system
Per site conditions the total-air feedforward was dropped. The superheat setpoint is not a constant but load-related: Fig. 1 uses first-stage pressure as the load signal, summed through a function generator with the operator's bias to form the setpoint. Because the setpoint-to-load relation differs between constant-pressure and sliding-pressure operation, two function generators are used — CLB-FX1 for constant pressure, CLB-FX2 for sliding pressure; per commissioning, the first-stage-pressure addition to the setpoint has been zeroed.
Auto/manual selection and interlocks are in Fig. 2: without MFT and above 30% load (37.5 MW), if both superheat spray-valve commands exceed 1%, the spray water block valve opens; on MFT or below 30%, any of actuator fault, control fault, bad superheater-outlet signal or bad secondary-desuperheater outlet signal forces the sprays to manual; when both spray-valve commands fall below 0.5%, the block valve closes.
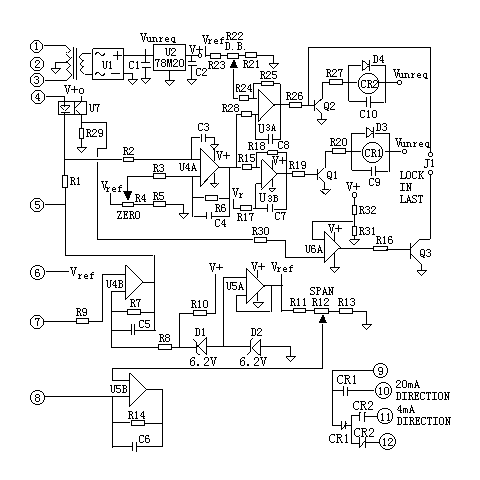
Fig. 2 Auto/manual control and interlock logic
The Limitorque actuator opens and closes the spray valve while limiting stem torque and thrust, protecting all valve operating parts against overload, mispositioning or jamming (Fig. 3).
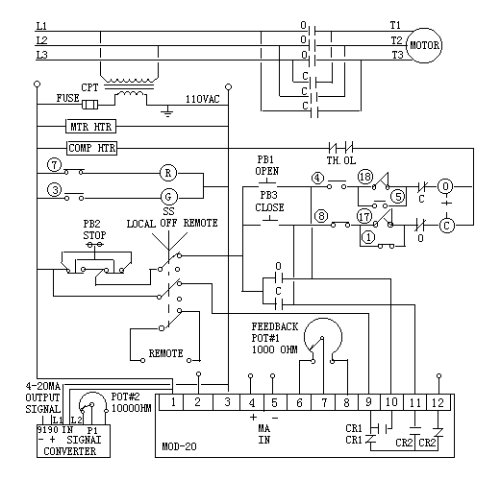
Fig. 3 L-120 actuator principle
In LOCAL mode the PB1 open and PB2 close buttons on the actuator panel operate it: pressing either energises the open or close coil, closing main-circuit contact (O) or (C) — used during commissioning and emergencies. In REMOTE mode the output relays CR1/CR2 on the servo board close control-circuit contacts (O)/(C) — these parallel PB1/PB2. In OFF, or with PB2 pressed, the 115 V AC control supply is cut and only the handwheel works. Travel switches 3 and 7 drive the panel red/green lamps; travel switches 1, 5, 4, 8 and torque switches 17, 18 serve full-open, full-close and intermediate limits; normally-closed contacts (O) and (C) provide open/close interlocking.
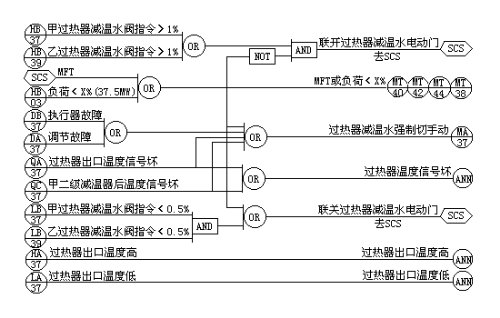
Fig. 4 MOD-20 servo board principle
In Fig. 4, after transformation, rectification, filtering and regulation, V+ powers the op-amps. The DCS command at terminals 4/5 is compared with the feedback at 7/8; the larger decides whether CR1 or CR2 energises. Span, zero and dead band adjust via potentiometers R12, R4 and R22.
Commissioning after installation:
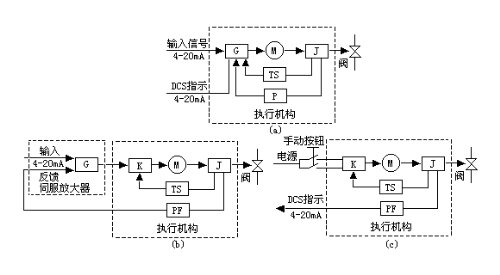
Bernard SD actuators come as modulating (a), external-servo (b) and remote-control (c) types: modulating units serve first superheat, first reheat and second reheat; the external-servo (CR-2) type serves second superheat; the remote type serves first-stage desuperheating (Fig. 5).
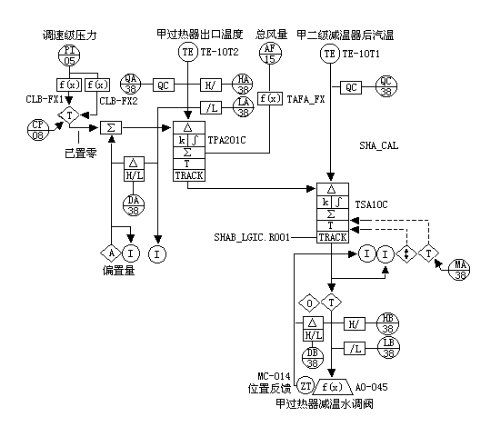
Fig. 5 Bernard SD principle (G: GAMX-2000 servo amplifier; M: motor; J: reducer; TS: torque/travel limiter; P: travel sensor potentiometer; PF: position transmitter)
Layout and wiring of motor, limit switches, servo and transmitter in the modulating unit are shown in Fig. 6.
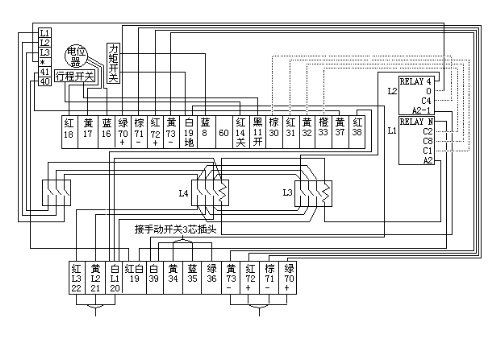
Fig. 6 Bernard SD modulating actuator principle
A bevel gear on the clutch sleeve's upper drive lug drives the gear limit switches, so the switches connect directly to the actuator output and, correctly set, track valve position in manual as in electric operation. The worm and shaft pass through two spring assemblies: when torque arises the worm moves axially against a spring; each assembly is pre-calibrated so a given compression means a given torque; the worm's motion trips the torque switch, cutting motor power. Torque switches are adjustable to pre-set torques.
Phase check: with the cam turning clockwise, press the OPEN switch with a screwdriver — the actuator must stop. If not, cut power immediately, swap any two supply phases and recheck. Clockwise cams use the CLOSE switch the same way.
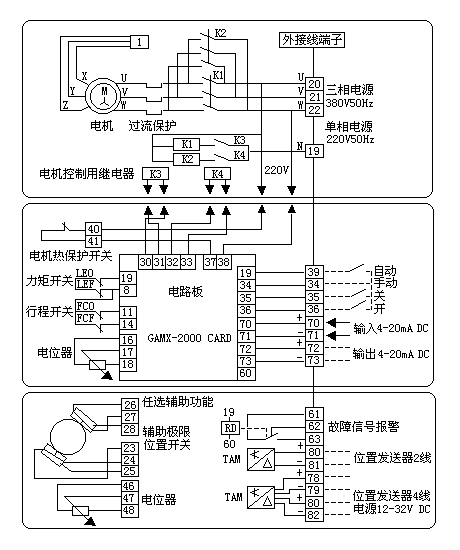
Fig. 7 Bernard SD wiring principle
In service the servo sometimes fails to trigger open or close, or the small relay contacts burn from arcing. Beyond replacing spares, try: if the servo board fails, disconnect the two small black plugs (to the small relays) and wire the servo's two switch lines to the upper terminals of the main contactor coil, disconnecting its original 220 V (powered contact). If the servo output is a dry contact, keep the original 220 V line to the coil, wire the servo switch lines to the lower terminals, and earth to terminal 19.






